Key Concepts:
- Drone simulator
- Python programming for drones
- Drone object instantiation
- Drone connection
- Takeoff, forward movement, landing, rotation
- Coordinate system in the simulator
- Applications: image capture, keyboard control, line following, obstacle courses, drone chasing, surveillance
Drone Simulator Overview
The video introduces a new drone simulator designed to facilitate learning drone programming using Python. The core idea is to create a realistic simulation environment where Python code directly controls a virtual drone, mimicking the behavior of a real-world drone.
Basic Drone Control
- Drone Object Creation: The first step involves creating a drone object in Python:
drone = Drone(). This instantiates a virtual drone within the simulator. - Connection: The drone object is then connected to the simulator using
drone.connect(). This establishes the communication link between the Python code and the simulated drone. The connection process is designed to be similar to that of a DJI Tello drone. - Takeoff and Movement: Basic commands like
drone.takeoff()initiate the drone's ascent. Forward movement is achieved usingdrone.forward(distance_in_cm). For example,drone.forward(50)moves the drone 50 cm forward. - Landing: The
drone.land()command brings the drone back to the ground. - Example Script: The initial example script demonstrates a simple sequence: takeoff, move forward 100 cm, and land.
Coordinate System and Rotation
The simulator includes a map that displays the drone's position. This allows for precise navigation. The video demonstrates moving the drone to a specific location on the map.
- Precise Movement: By observing the drone's position on the map, the presenter adjusts the
drone.forward()distance to reach a target location. For example, changing the forward distance from 200 cm to 220 cm. - Rotation: The
drone.rotate(angle_in_degrees)command rotates the drone. A negative angle indicates counter-clockwise rotation. For example,drone.rotate(-90)rotates the drone 90 degrees counter-clockwise. - Combined Movements: The video demonstrates a sequence of forward movement, rotation, and further forward movement to precisely position the drone in a target area.
Advanced Applications and Future Development
The video highlights potential future applications and features of the drone simulator:
- Image Capture: Simulating image capture from the drone's camera.
- Keyboard Control: Implementing keyboard-based drone control.
- Line Following: Programming the drone to follow a predefined line.
- Obstacle Courses: Navigating the drone through simulated obstacle courses.
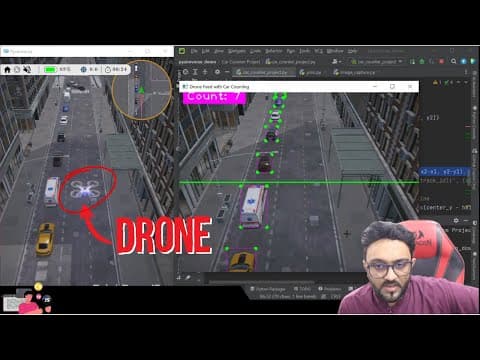
- Drone Chasing: Simulating scenarios where the drone chases a moving target (e.g., a car).
- Surveillance: Implementing surveillance applications like traffic control.
Conclusion
The drone simulator aims to provide a user-friendly environment for learning drone programming with Python. The simulator allows users to write code that directly controls a virtual drone, mimicking real-world drone behavior. The video showcases basic drone control functionalities and outlines potential future applications, emphasizing the importance of drone programming skills in the future. The presenter solicits feedback on the project's potential and relevance as a learning tool.
AI summaries can miss context or contain errors. Check important details against the original video.