Key Concepts
- AI-powered Drone Programming: Using AI tools like Cursor to generate and modify drone code.
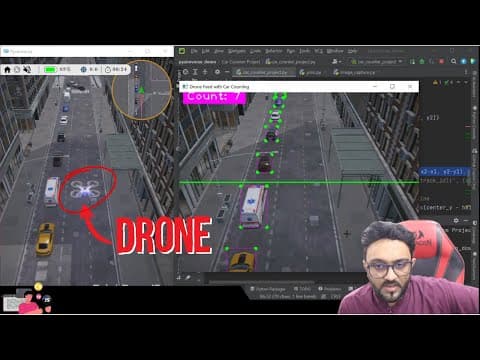
- Pymverse: A drone simulator for learning, competitions, and real-world scenario testing.
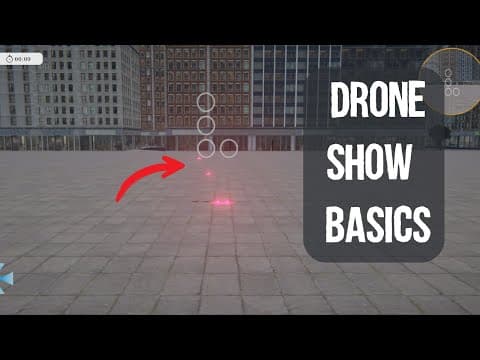
- Obstacle Avoidance: Programming a drone to autonomously navigate through hoops.
- Computer Vision: Using image recognition (YOLO) to detect hoops in the drone's camera feed.
- PID Control: Implementing a Proportional controller (P) for autonomous drone movement.
- Data Collection and Labeling: Gathering and annotating images for training object detection models.
- Kickstarter Campaign: Launching a crowdfunding campaign to fund Pymverse development.
Pymverse Simulator and its Purpose
The speaker introduces Pymverse, a drone simulator launching on August 5th (a Tuesday). It aims to bridge the gap between drone hardware and programmable control, offering a software solution for learning and experimenting with drone programming in real-world scenarios.
- Key Features:
- Multiple scenarios for challenges, competitions, and learning.
- Half-screen design for simultaneous coding and simulation viewing.
- Connection to simulated drone for feed access.
- Example codes (basics, image capture, YOLO) for different scenarios.
- Pricing Model:
- Some scenarios will be free to download and run.
- Competitions and live sessions will be part of a paid subscription.
- Lifetime deal available for Kickstarter backers (one-time payment for all future content and live sessions).
- Motivation:
- The TE drone is discontinued and hard to find.
- Many companies offer drones as ready-made products, limiting programmability.
- Pymverse provides a safe and cost-effective environment for learning and testing drone code.
- Simulates real-world physics to replicate drone behavior accurately.
Obstacle Course Challenge: Autonomous Hoop Navigation
The core of the session involves programming a drone to autonomously navigate an obstacle course consisting of hoops.
- Goal: The drone should detect hoops, identify the largest one, and move towards it.
- Methodology:
- Data Collection:
- Write code to move the drone using keyboard input (arrow keys).
- Capture images of the drone's camera feed using the 'S' key.
- Store the images in an output folder for labeling.
- Model Training:
- Label the collected images by drawing bounding boxes around the hoops.
- Train an object detection model (YOLO) using the labeled data.
- The speaker refers to their free object detection course on YouTube for detailed instructions.
- Autonomous Navigation:
- Use the trained YOLO model to detect hoops in real-time from the drone's feed.
- Implement a Proportional (P) controller to adjust the drone's yaw (rotation) based on the hoop's position in the image.
- Maintain a constant forward speed.
- Count the number of hoops passed and land the drone after passing two hoops.
- Data Collection:
Step-by-Step Code Development
The speaker demonstrates the coding process using Cursor, an AI-powered code editor.
- Collecting Data (collecting_data.py):
- Import necessary libraries (e.g.,
pyimverse,cv2). - Connect to the drone and turn on the camera stream.
- Implement keyboard controls for drone movement (W/A/S/D for forward/left/backward/right, T for takeoff, L for land).
- Save images to an output folder when the 'Z' key is pressed.
- Import necessary libraries (e.g.,
- Hoop Detection (hoop_detection.py):
- Integrate the YOLO model (
model.pt) with the image capture code. - Display the drone's camera feed with bounding boxes around detected hoops.
- Integrate the YOLO model (
- Autonomous Hoop Course (autonomous_hoop_course.py):
- Implement a P controller to adjust the drone's yaw based on the hoop's center X coordinate.
- Define a
PIDControllerclass withKP,KI, andKDvalues (initially using onlyKP). - Implement logic to count the number of hoops passed and land the drone after passing two.
Technical Details and Challenges
- RC Control: Using
drone.rc_controlto control the drone's speed and direction. - Image Processing: Using OpenCV (
cv2) to process the drone's camera feed and draw bounding boxes. - PID Tuning: Adjusting the
KPvalue to achieve stable and accurate hoop tracking. - Challenges:
- Initial issues with the AI-generated code (e.g., incorrect key mappings, takeoff command not working).
- Drone moving in the wrong direction due to incorrect P controller implementation.
- Inaccurate hoop detection leading to premature or missed hoop counts.
- Drone continuing to move forward for too long after passing a hoop.
- Balancing speed and accuracy to avoid collisions.
P Controller Implementation
The speaker implements a Proportional (P) controller to autonomously adjust the drone's yaw.
- Goal: To center the drone on the largest detected hoop.
- Method:
- Calculate the error as the difference between the image center X coordinate (320) and the hoop's center X coordinate.
- Multiply the error by the
KPvalue to get the yaw output. - Clamp the yaw output to a range of -3 to 3 to limit the drone's rotation speed.
- Apply the yaw output to the drone's
rc_control.
- Tuning:
- The speaker initially sets
KIandKDto zero and focuses on tuningKP. - They start with a small
KPvalue (0.01) and gradually increase it until the drone tracks the hoop effectively.
- The speaker initially sets
- Issue: The initial implementation caused the drone to move in the wrong direction, which was fixed by inverting the error calculation.
Key Arguments and Perspectives
- Importance of Simulation: The speaker emphasizes the value of using a simulator like Pymverse for learning and testing drone code before deploying it on real hardware.
- AI as a Tool: The speaker advocates for using AI tools like Cursor to accelerate the coding process, but also acknowledges the need for human oversight and debugging.
- Bridging the Gap: The speaker aims to bridge the gap between drone hardware and programmable control, making drone technology more accessible to students and researchers.
- Future of Drones: The speaker believes that drones will become increasingly prevalent in various industries and applications, creating a demand for skilled drone programmers and engineers.
Notable Quotes
- "AI is taking over and now we need to use it as a tool."
- "We are trying to create a software which will be easy for everyone to use and then you will be able to go through uh different scenarios and real world scenarios."
- "If you were to learn how to pilot, right? If you wanted to become a pilot, then you would not go directly fly a plane. You would first learn for a few hundred hours how exactly can you fly."
Synthesis/Conclusion
The YouTube session demonstrates the use of AI-powered coding tools and a drone simulator (Pymverse) to develop an autonomous hoop navigation system. The speaker walks through the process of data collection, model training, and P controller implementation, highlighting the challenges and solutions encountered along the way. The session emphasizes the importance of simulation for safe and cost-effective drone programming and promotes the upcoming Pymverse Kickstarter campaign. The key takeaway is that AI can be a valuable tool for drone programming, but human expertise is still essential for debugging and refining the code. The speaker successfully demonstrates a functional autonomous drone system within a short timeframe, showcasing the potential of Pymverse as a learning and development platform.
AI summaries can miss context or contain errors. Check important details against the original video.